运动学自行车模型:
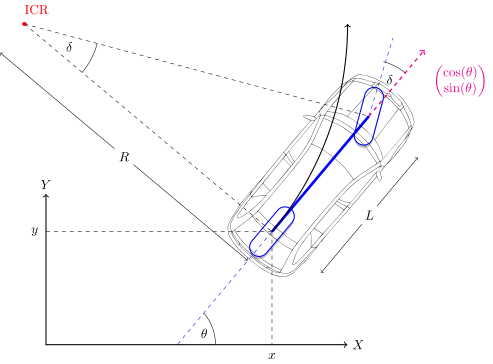
https://thomasfermi.github.io/Algorithms-for-Automated-Driving/Control/BicycleModel.html
以车辆后轴中心建立坐标系,则车辆状态及运动学为:
\[
\mathbf{\dot{X}} = \begin{bmatrix} \dot{x} \\ \dot{y} \\ \dot{\theta} \\ \dot{v} \end{bmatrix} = \begin{bmatrix} v cos(\theta) \\ v sin(\theta) \\ v tan(\delta)/L \\ a \end{bmatrix}
\]
其中,\(x,y,\theta\)为位置和姿态\(v,a\)为速度加速度\(\delta\)为方向盘转角\(L\)为前后轮轴距。
动力学自行车模型:
车辆运动学自行车模型其实还隐含着一个重要的假设,那就是: 车前轮的方向即是车辆当前的速度方向,在实际车辆运动过程中,当车辆在以相对高的速度行驶时,车轮的方向并不一定车辆当前的速度方向,这个时候,我们引入车辆的动力学自行车模型。
Reference
[1] Vehicle Dynamics and Control
[1] https://zhuanlan.zhihu.com/p/149304322
[2] https://zhuanlan.zhihu.com/p/358227196
[3] https://zhuanlan.zhihu.com/p/359676274
[]